Autonomous Driving
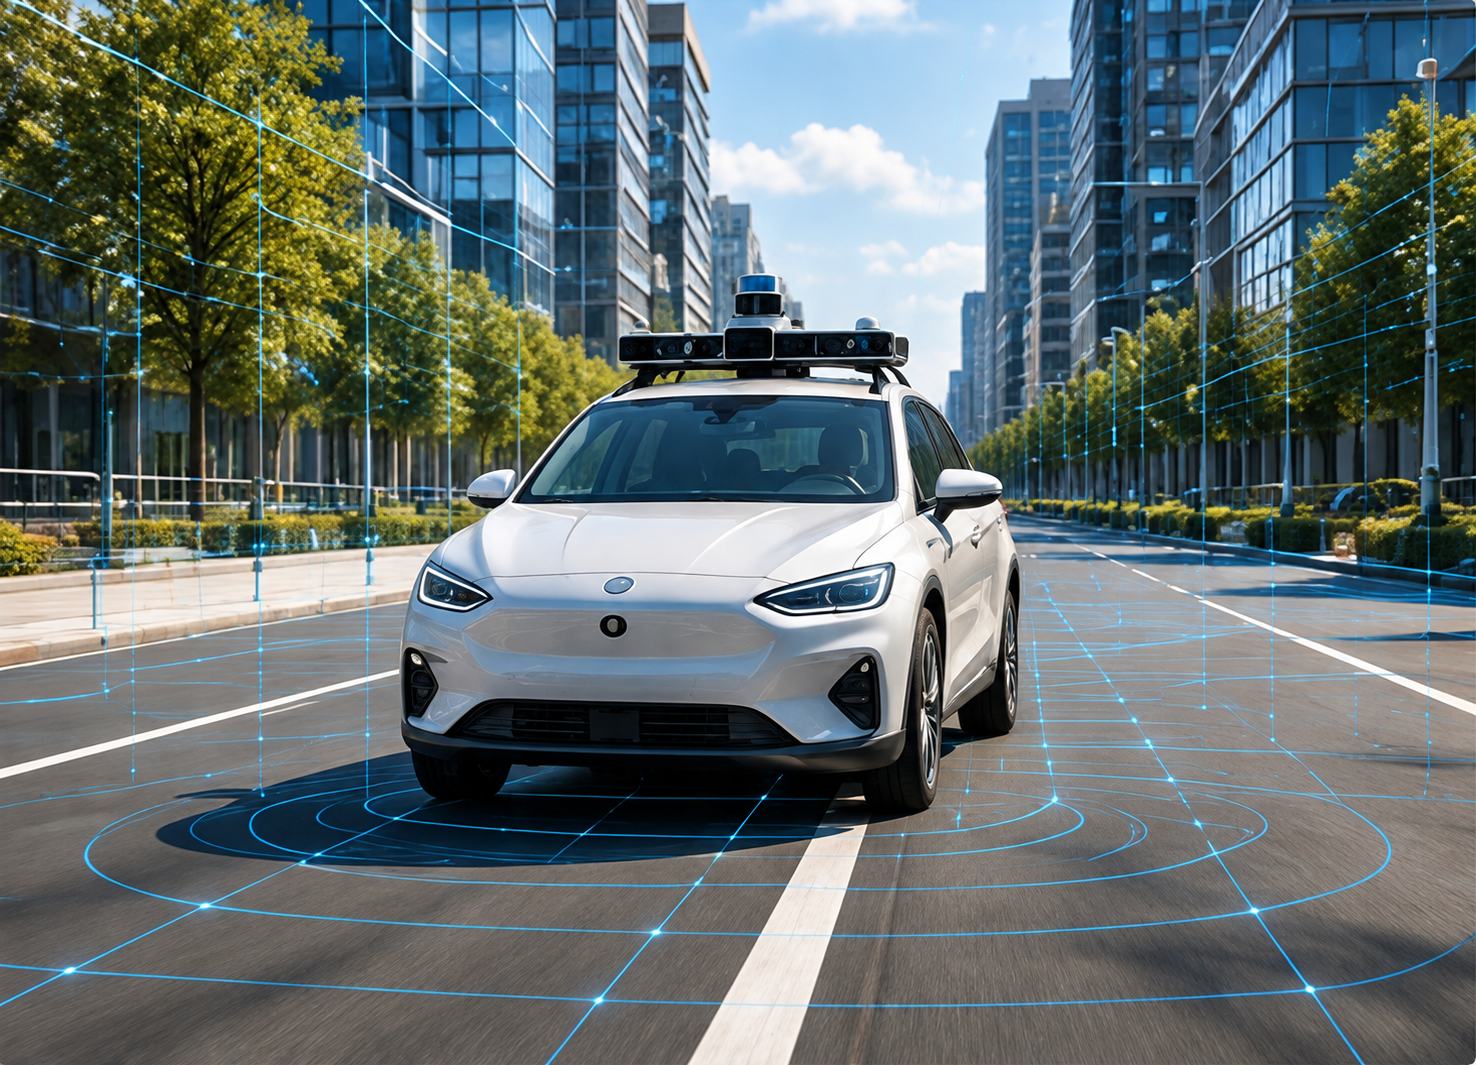
We develop next-generation autonomous driving systems for real-world scenarios. The AIDA – Artificial Intelligence Driving Autonomous research initiative covers the full spectrum of autonomous mobility challenges: from navigaune compiex uroan environments to tocking exteme ont road concitons.
Our work spans perception, planning, localization, and control algorithms. We integrate advanced sensor fusion, real-time decision-making. and robust vehicle control to enable safe and intelligent autonomous vehicles. Whether it’s city streets with unpredictable traffic or rugged terrain with minimal infrastructure. our systems are designed to handle the complexity of real driving.
Key Research Areas
Autonomous Racing – PoliMOVE Racing Team
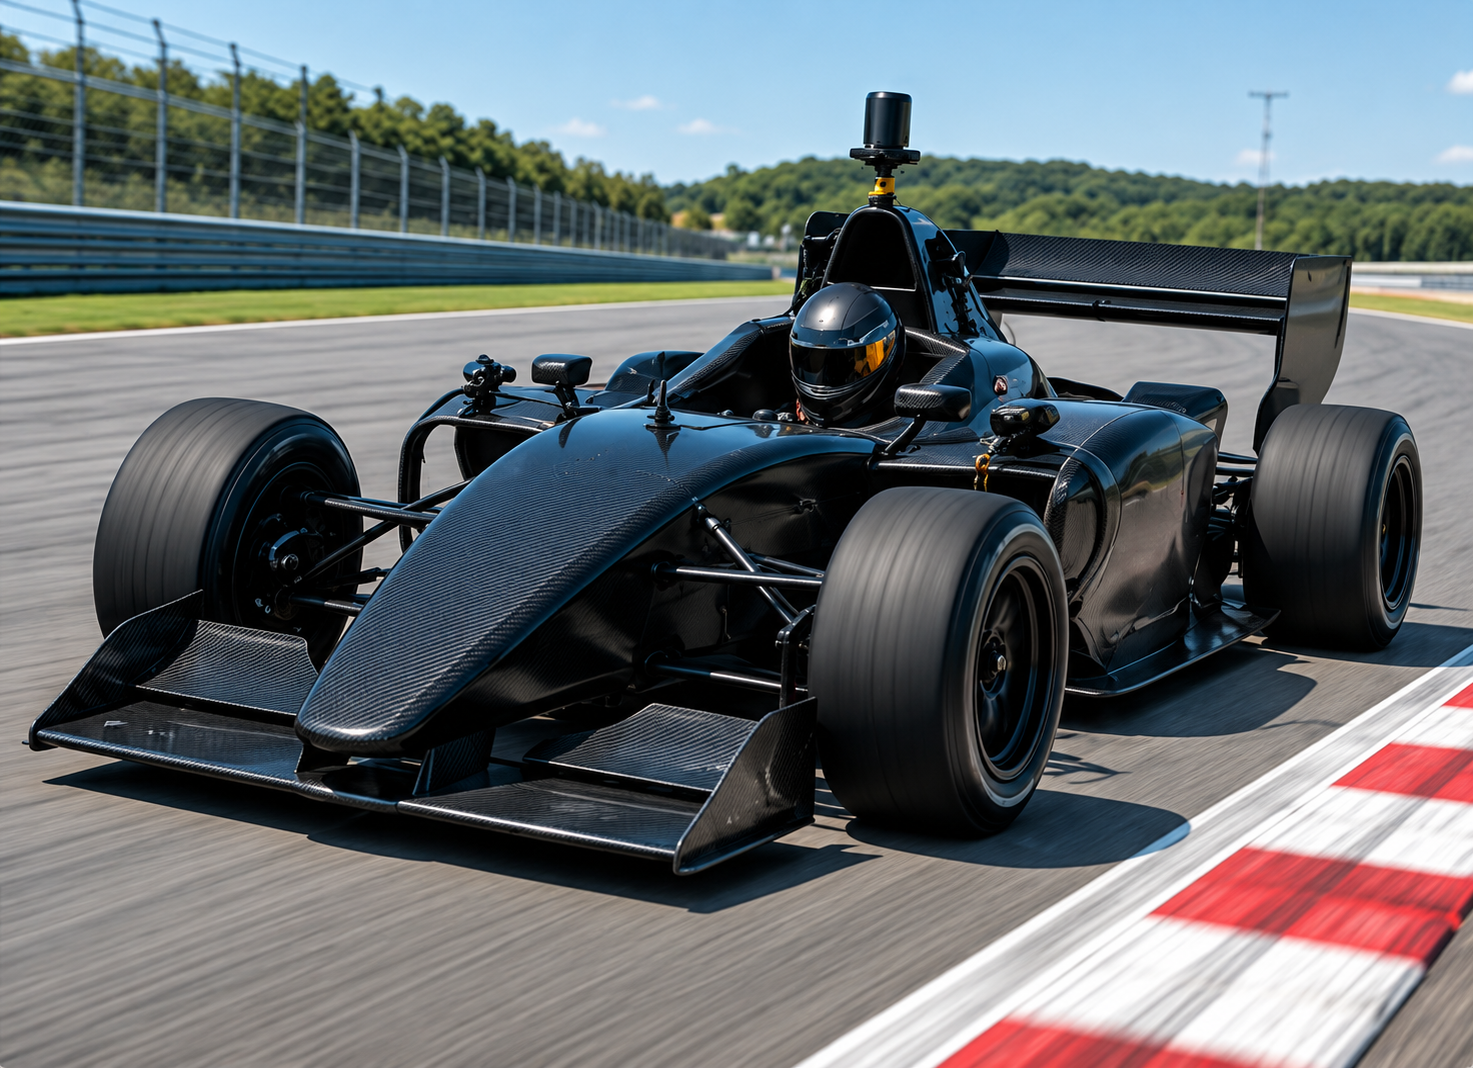
PoliMOVE is our autonomous racing team, competing at the frontier of vehicle performance and artificial intelligence.We develop autonomous racing algorithms that push the boundaries of what’s possible—vehicles that think and react faster than any human driver.
Racing is our ultimate test ground. In high-speed competition, control algorithms must achieve precision, robustness, and real-time performance under extreme constraints. The technologies we develop for racing accelerate innovation for road vehicles, including advanced path planning, predictive control, and optimization algorithms that operate at the edge of vehicle dynamics.
Currently competing in the Indy Autonomous Challenge and A2RL, we compete against the world’s top universities in head-to-head autonomous racing events.
Key Research Areas
Vehicle Dynamics & Control Systems
Advanced control systems are the foundation of modern mobility. Our research group develops sophisticated control technologies that enhance safety, performance, and efficiency across a wide range of vehicles and applications.
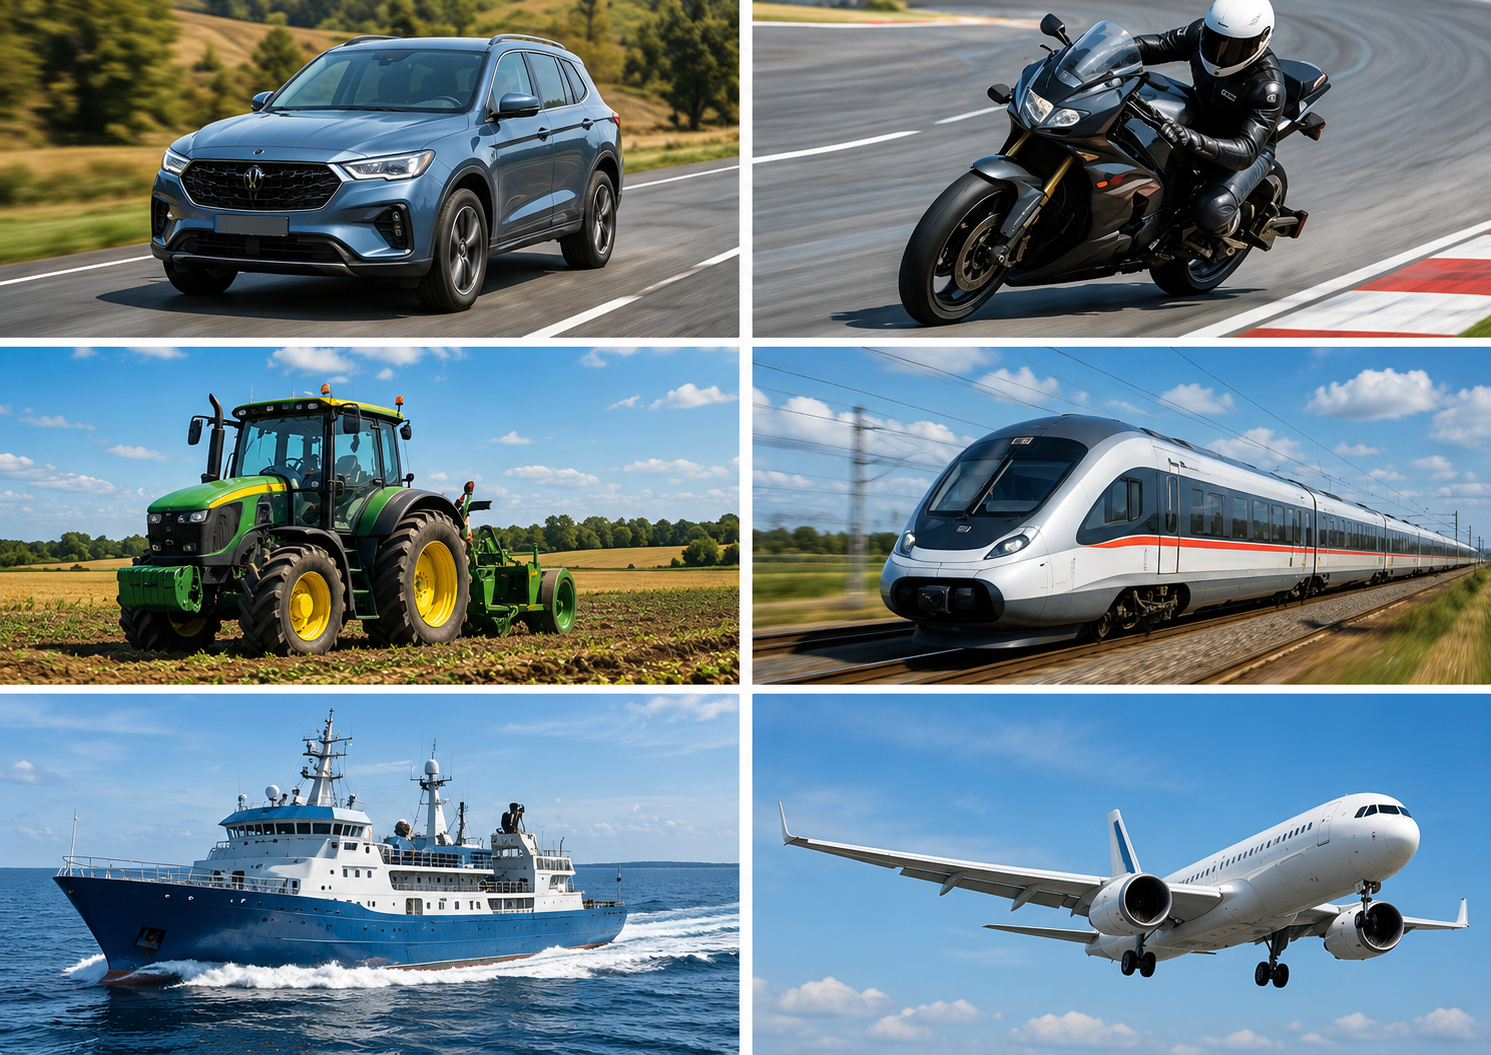
From electronic suspensions and braking systems to traction control and stability management, we engineer intelligent systems that respond in real-time to changing conditions. Our expertise extends beyond cars to motorcycles, electric bicycles, agricultural vehicles, trains, ships, and aerospace platforms.
Each vehicle presents unique challenges. We develop control-oriented dynamic models, apply advanced identification techniques, and design controllers optimized for specific applications. Whether improving comfort in urban vehicles, enabling precise maneuvers in off-road equipment, or ensuring stability in marine vessels, our control systems deliver measurable performance improvements.
Key Research Areas
Mobility Data Analysis
Data is the fuel of modern mobility innovation. Our research in mobility data analysis transforms raw vehicle and traffic data into actionable insights that drive smarter, safer, and more efficient transportation systems.
We develop advanced analytics, machine learning models, and data-driven identification techniques to understand vehicle behavior, predict system performance, and optimize operations. From analyzing driving patterns and vehicle health to understanding traffic dynamics and fleet performance, we extract value from data that would otherwise remain hidden.
Our black-box identification methods and data-based modeling approaches enable us to build accurate predictive models quickly, even when traditional analytical approaches fall short. These capabilities support everything from individual vehicle optimization to large-scale fleet management and smart city mobility initiatives.